Haofei Hou
Haofei Hou
Home
Publications
Projects
Posts
Light
Dark
Automatic
HRI
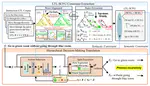
Linear Temporal Logic Translation via Human-Inspired Self-Constrained Reasoning for Robot Task Specification
We introduce Self-Constrained Reasoning, a novel approach that embeds an LTL-specific synchronous grammar into hierarchical reinforcement learning, enabling LLM-based task specification while preserving formal validity and generalization.
Haofei Hou
,
Fanxu Meng
,
Shunyi Zhao
,
Kairui Yang
,
Mengchen Cai
,
Lecheng Ruan
,
Qining Wang
PDF
Cite
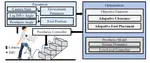
Knee Prosthesis Stair Ascending with Adaptive Clearance and Foot Placement
This paper presents an optimization-based control framework for powered knee prostheses to perform stair ascent.
Wenduo Zhu
,
Mengchen Cai
,
Haofei Hou
,
Shunyi Zhao
,
Lecheng Ruan
,
Qining Wang
PDF
Cite
Obstacle Avoidance for Knee Prostheses via Direct Integration of Environment Information
This paper presents a novel framework for powered knee prostheses to achieve obstacle avoidance by directly integrating environmental information.
Wenduo Zhu
,
Mengchen Cai
,
Haofei Hou
,
Shunyi Zhao
,
Lecheng Ruan
,
Qining Wang
PDF
Cite
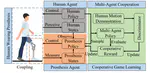
Prosthetic Control by Learning: A Multi-Agent Cooperative Game Framework
We develop a model-free reinforcement learning framework that enables the prosthesis to adapt to diverse human movement patterns through cooperative policy learning.
Haofei Hou
,
Wenduo Zhu
,
Lecheng Ruan
,
Qining Wang
PDF
Cite
Cite
×